 motors.mdx
1--- 2title: Movement with Strudel 3layout: ../../layouts/MainLayout.astro 4--- 5 6import { MiniRepl } from '@src/docs/MiniRepl'; 7import Box from '@components/Box.astro'; 8import QA from '@components/QA'; 9 10# Controlling motors with Strudel 11 12Strudel is mainly made for making music, but it's possible to pattern other things with it, including motors. 13 14We're going to use a microcontroller for this, called an "[Inventor 2040W](https://shop.pimoroni.com/products/inventor-2040-w)", which is 15a [Pico W](https://shop.pimoroni.com/products/inventor-2040-w?variant=40053063155795) with extra ports added including some for controlling motors. 16 17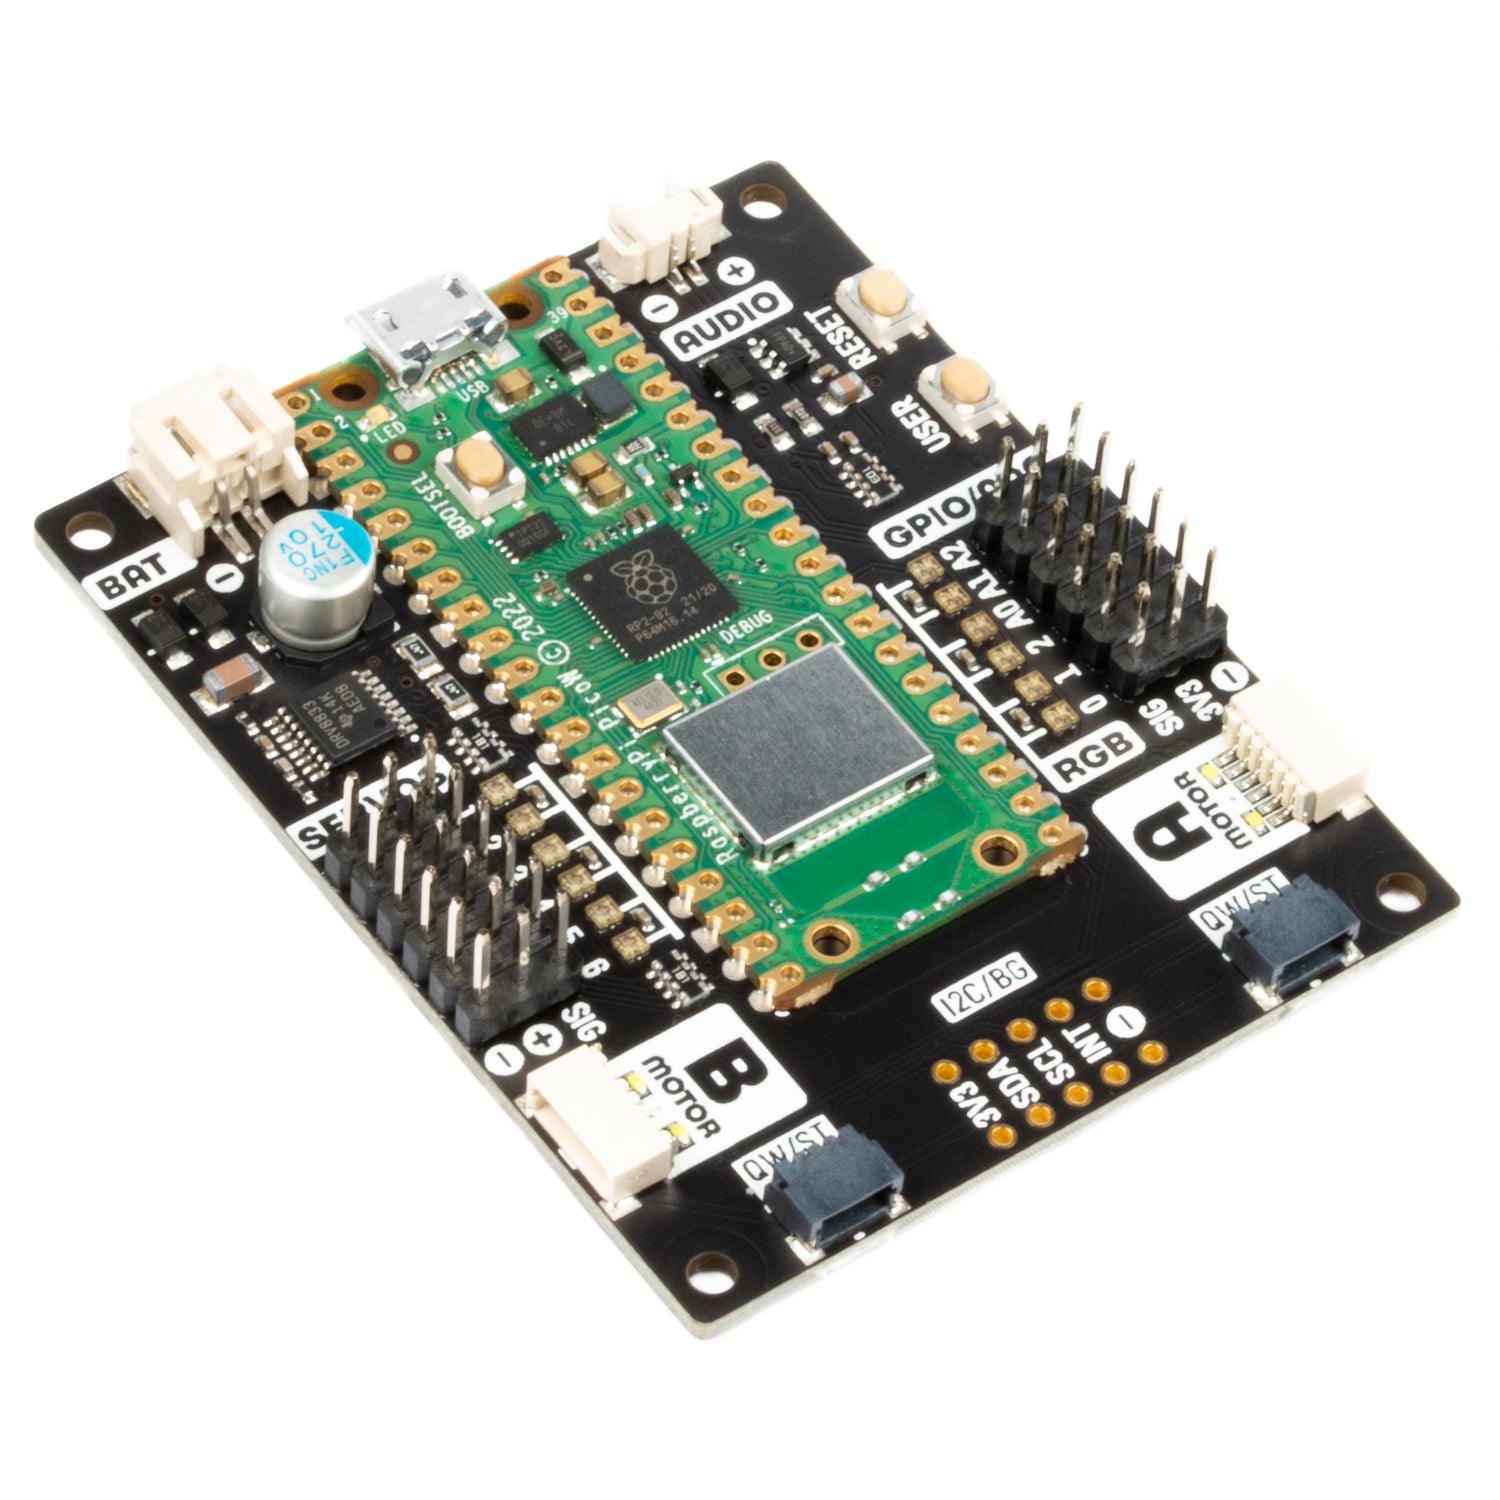 18 19## Technical details 20 21Feel free to gloss over these! 22 23- The Inventor 2040W connects to the internet wirelessly, and it can power from a battery or USB. Hopefully the batteries last! 24- It's running [some code](https://github.com/patternclub/alpacalab/blob/main/course/main.py) that listens for messages using an "Internet of Things" network protocol (called MQTT). When it receives a message, it moves a motor. 25- It connects to a small server (running software called 'mosquitto') on Alex's laptop. 26- Strudel can send these messages instead of triggering sounds - that's how we use it to pattern movement. 27 28## First movement 29 30Let's get a motor running! 31 321. Note the letter drawn on a label on the back of the microcontroller. 33 342. Plug a battery into your microcontroller. 35 363. Plug a motor into 'servo' (not motor) plug numbered 1, with the yellow (lightest) cable closest to the '1', and the brown (darkest) cable outward 37 384. Run the below to set up some values, changing the `x` in 'robot('x')` to the letter on your microcontroller. 39 40<MiniRepl 41 client:visible 42 tune={` 43 $: move("-60 80").motor("0").robot('x'); 44 `} 45/> 46 47<Box> 48 49If you refresh the page, you'll need to change the letter to match your robot again. 50 51If your motor starts moving unexpectedly, someone else might have put your letter in by mistake! 52 53Note that in the above, we start counting motors from '0', so motor 1 on the board is motor 0 in the code. 54 55</Box> 56 57## Patterning movement 58 59Many strudel features for playing with sound patterns will work when 60playing with motor patterns. Try playing with the mininotation in the 61`move` command: 62 63<MiniRepl 64 client:visible 65 tune={` 66$: move("-10 0 10 [20 30]*2").motor("0").slow(2).robot('x') 67 `} 68/> 69 70The move instructions are in the range from -90 to 90. 71 72<box> 73 If your motors stop working at some point, and your code looks right, try pressing the 'reset' button on the 74 microcontroller. 75</box> 76 77It's possible to make smooth movements based on different 'waveforms', for example a smooth sinewave: 78 79<MiniRepl 80 client:visible 81 tune={` 82$: move(sine.range(-30, 30).segment(16)).motor("0").slow(2).robot('x'); 83 `} 84/> 85 86The movement is still quite jerky, because the 'segment' command is 87only taking 16 positions from the sinewave. Try increasing it to 32 or 64. It's best not too much higher than that, as the microcontroller 88might get overwhelmed with a backlog of instructions! 89 90<box> 91 Try replacing `sine` with other waveforms: `saw` (sawtooth wave), `tri` (triangular wave) are good, and there is also 92 `rand` (random wave) and `perlin` (a kind of smoothed-out randomness). 93</box> 94 95## Patterning more than one motor 96 97You can pattern the `motor` command separately from the `move` one: 98 99<MiniRepl 100 client:visible 101 tune={` 102$: move("-10 0 10 [20 30]*2").motor("0 1").slow(2).robot('x'); 103 `} 104/> 105 106Alternatively, you can pattern two motors in separate patterns. The below sends the same pattern for the first two motors, but with the second one running slower: 107 108<MiniRepl 109 client:visible 110 tune={` 111 112$: move("-10 0 10 [20 30]\*2").motor("0").slow(2).robot('x'); 113 114$: move("-10 0 10 [20 30]\*2").motor("1").slow(3).robot('x'); 115 116`} 117/>